
 Project Pages


Predictive Semantic Safety


Barrier-Rate Guided MPPI

OcclusionCBF for Occluded Dynamic Obstacles


SEAMLiS: Safe Multi-Robot Exploration

Online Adaptive CBF

[CDC 2026] Review of Backup-Based Safety Filters

Policy Library CBF

[ICRA 2026] Safe Model Predictive Diffusion
[ICRA 2026] Dynamic Parabolic CBF

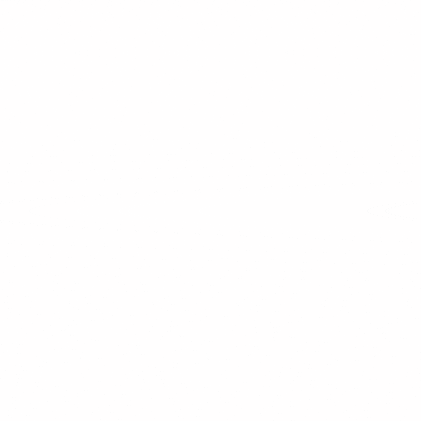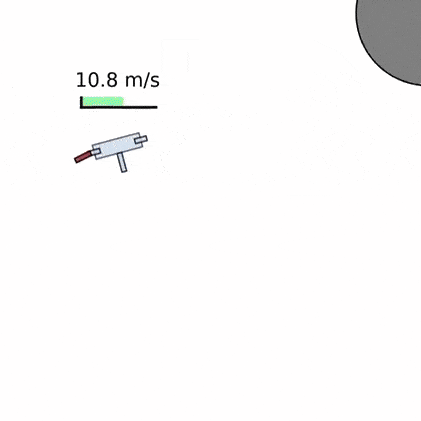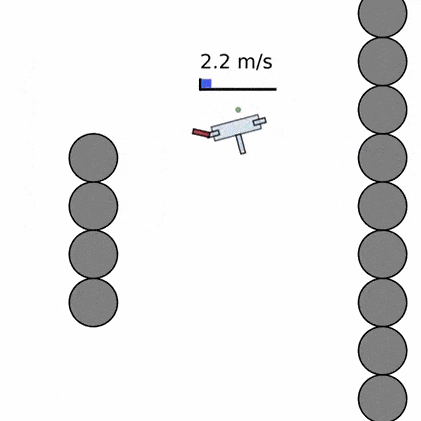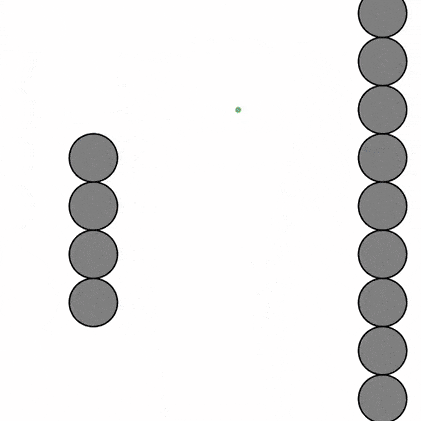
[CDC 2025] How to Adapt CBFs?

[RSS 2025] Certifiably-Correct Mapping

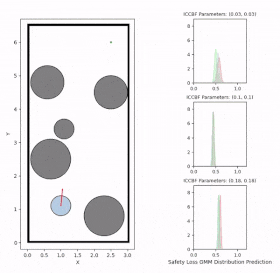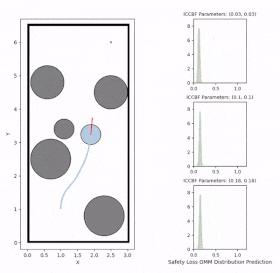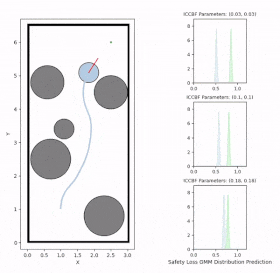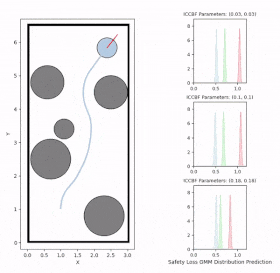
[ICRA 2025] Online Adaptive ICCBF

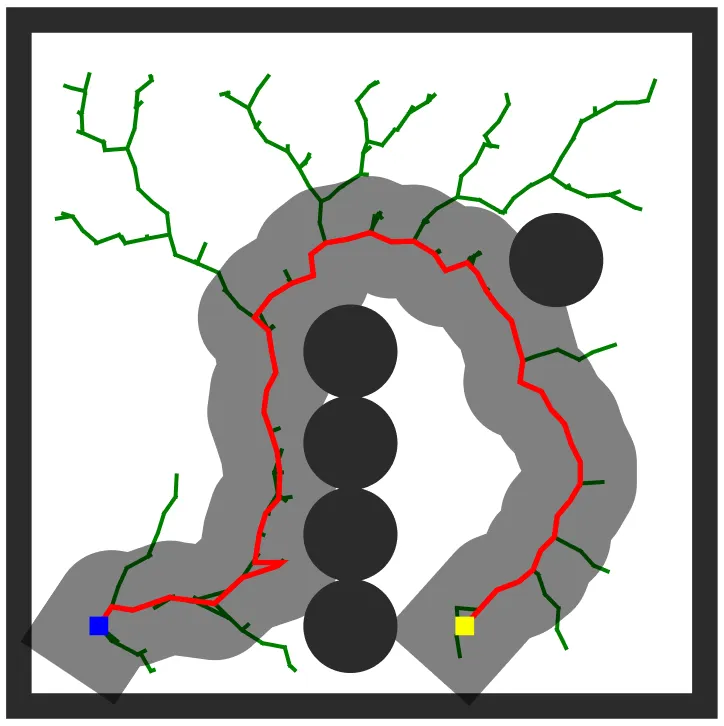
[RA-L 2025] Visibility-Aware RRT*


[RSS 2023] Bridging Active Exploration and Uncertainty-Aware Deployment

[RA-L 2023] Learning Terrain-Aware Kinodynamic Model for Off-Road Driving

[RA-L 2022] Smooth MPPI
 Other Projects
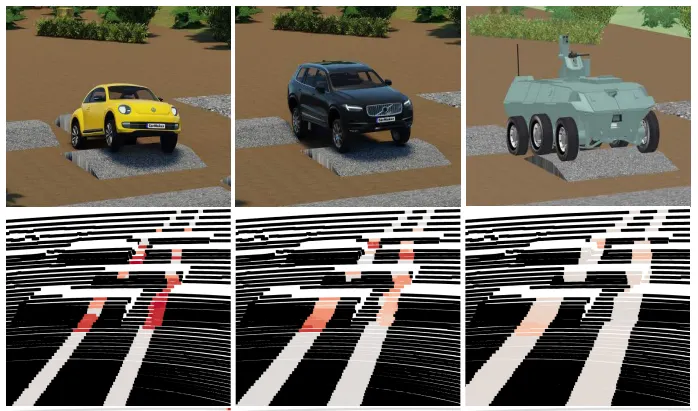
Traversability Estimation
Deep Learning
Traversability
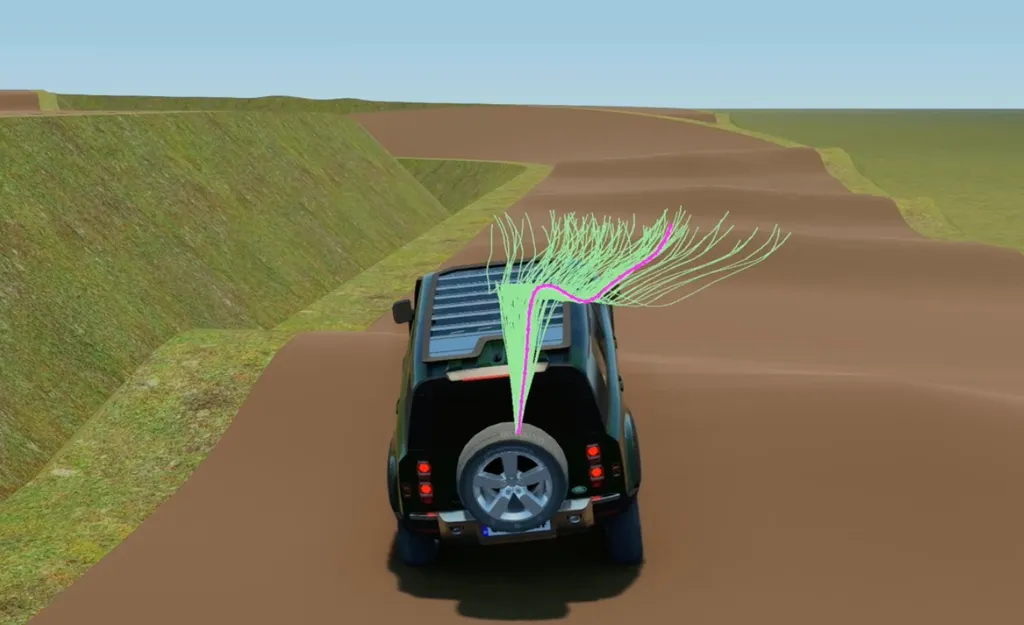
Off-Road Autonomous Driving
Dynamic Learning
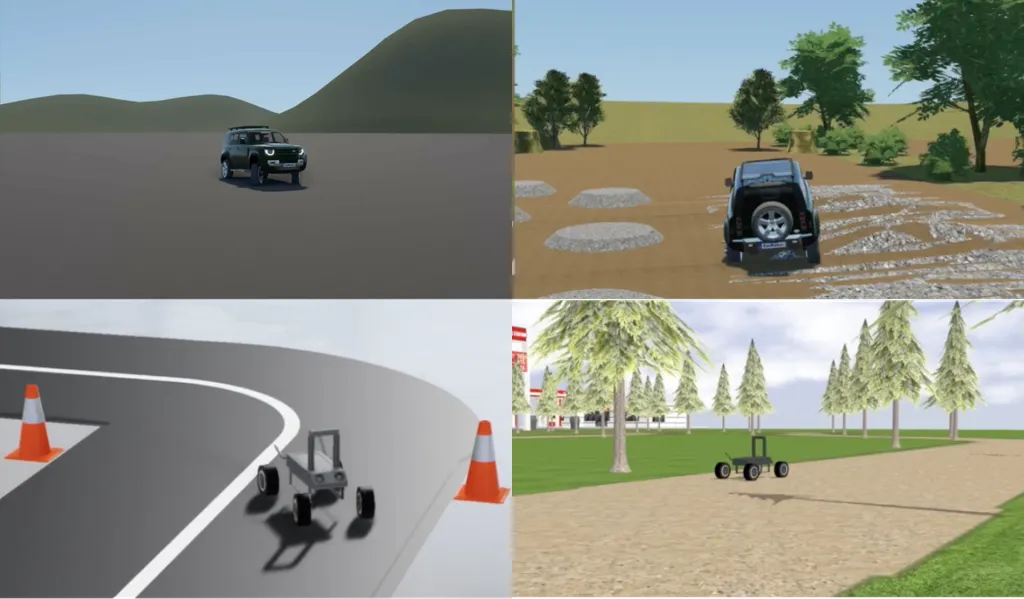
Uncertainty-Aware Active Exploration
MBRL
Dynamic Learning
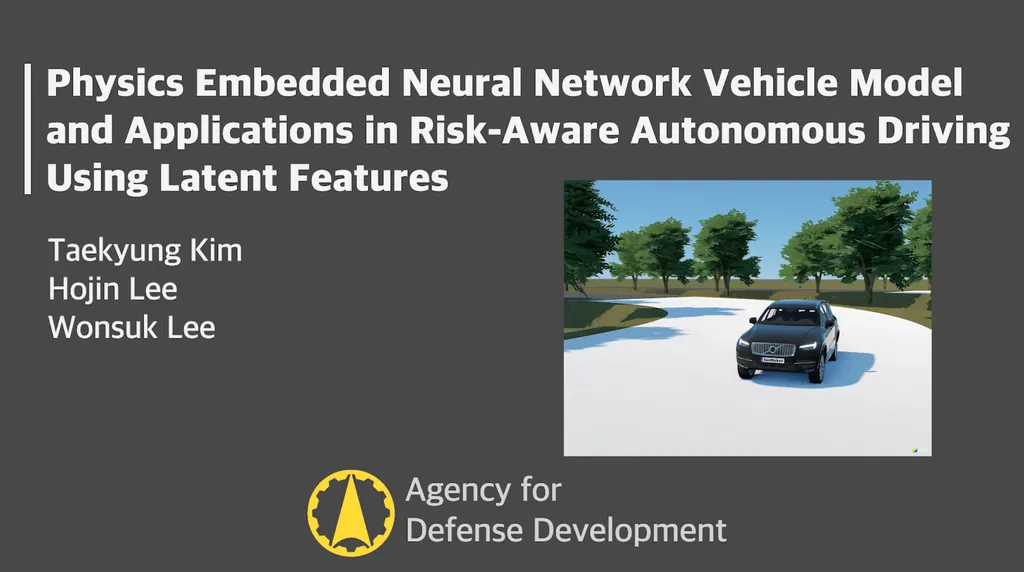
Learning-Based Vehicle Model and Control
Dynamic Learning
Control


Smooth MPPI
Control
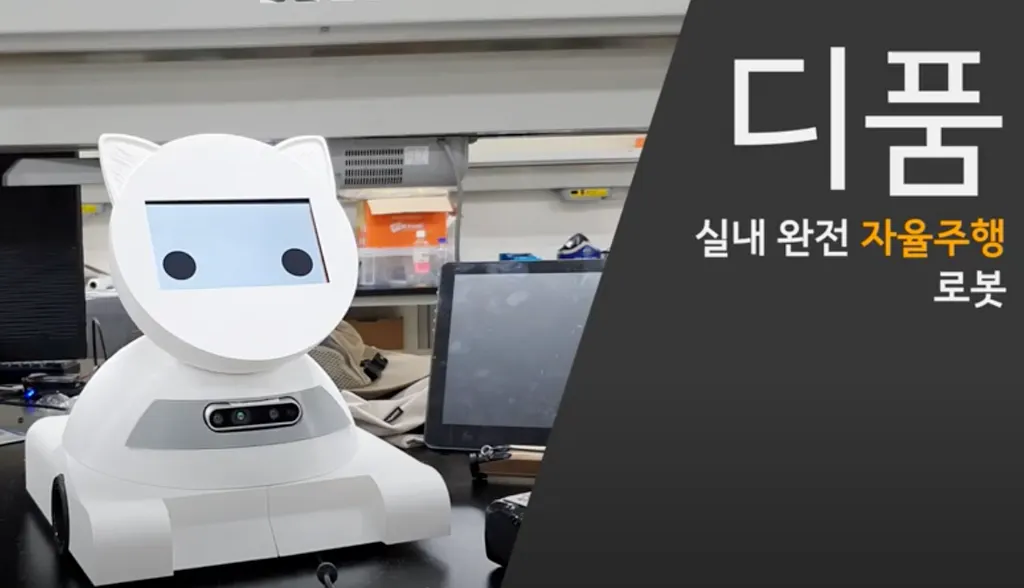

DPoom
Robot System
Navigation